Operator capturing a real-world manipulation task in an industrial workspace

Data operations · under Leviathan Group

Real-world data. Expert operators. Built to deliver.

OmniSource sources, annotates, engineers and quality-controls the real-world data behind robotics, foundation-model and industry AI programs. Buy an existing data pack, commission new data for a specific task, or hand us your own data to process and operate continuously.

data product directions
33data product directions
delivery services
7delivery services
engagement models
6engagement models

Three ways to start

Purchase, commission or operate — the data layer meets you where you are.

01

Buy a proven pack

Select fixed tasks, fields and versions from licensable inventory, or filter and reshape it to your pipeline.

Standard License · Semi-Custom Pack

02

Commission new data

Capture new tasks, scenes, devices and protocols from scratch, with design, collection, annotation and acceptance.

Custom Collection · Exclusive Program

03

Hand us your data

Process customer-owned logs and assets, or run a staffed team operating your data workflow continuously.

Continuous Service · Managed Team

Compare all six engagement models ↗

Verified samples

Real capture frames with measured specifications.

These four samples are drawn directly from the OmniSource data catalog. Frame counts, resolution, duration and label counts are exact; every other product is scoped per project.

Dual-arm robot folding a white towel on a table, real capture frame
S01Verified sample

Robot towel folding

Dual-arm master–follower teleoperation folding a towel, captured from three synchronized viewpoints.

Views
Front / left / right
Resolution
640 × 480 @ 20 fps
Clips
≈ 354.2 s and 886.6 s
Data pack contents

MP4 + JSON. Position and rotation of master/follower left and right arms, gripper, and joint fields.

Related product: P01 ↗
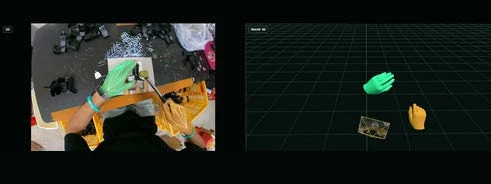
Split view: first-person assembly workspace and a 3D hand-tracking visualization on a grid
S02Verified sample

Workpiece assembly

Egocentric assembly task shown as 2D video alongside a synchronized 3D two-hand visualization.

Frames
1,219
Resolution
1920 × 1440
Duration
≈ 40.67 s
Labels
8 English action labels
Data pack contents

Original video + visualization video + HDF5. 3D structure of both hands, camera information, and semantics.

Related product: P03 ↗
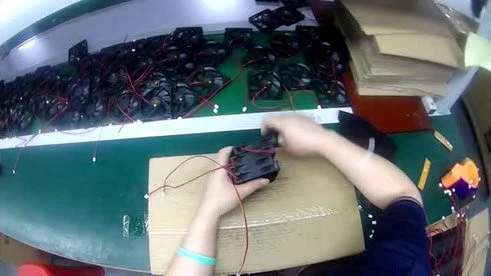
First-person view of hands sorting components and cables into packaging
S03Verified sample

Material sorting

First-person grasping and packing task, with per-action start and end times.

Frames
224
Resolution
1920 × 1080
Duration
≈ 7.46 s
Labels
9 English action labels
Data pack contents

Original video + visualization video + HDF5. Task description and action start/end times.

Related product: P02 ↗
First-person view of hands assembling small electronic parts with a screwdriver
S04Verified sample

Electronics installation

Fine two-hand manipulation and wiring on small components, with wrist and hand pose.

Frames
866
Resolution
1920 × 1080
Duration
≈ 28.86 s
Labels
2 English action labels
Data pack contents

Original video + visualization video + HDF5. Both-hand pose and wrist pose.

Related product: P11 ↗

Shared ego-sample fields: 21 3D joints per hand, MANO parameters, camera intrinsics and pose, timestamps, validity masks, and confidence. Precision and synchronization error are confirmed during project acceptance.

Solution paths

Combinations that map products to a training objective.

01

Real-robot and human demonstrations, hand structure, instructions, and action segments; splits by task and robot.

02

Scenes, objects, continuous interaction, and outcomes; preserves real/synthetic provenance and comparable evaluation sets.

03

Interaction and failure logs, human correction, and independent evaluation; builds the list for the next targeted collection batch.

Delivery services

Seven services from collection to managed operation.

Services & delivery ↗
  • 01

    Data Collection

    Raw data, task/device metadata, collection logs, batch lists and quality reports.

  • 02

    Annotation & Processing

    Label files, annotation guidelines, version history, review results and hard-case lists.

  • 03

    Data Engineering

    Versioned datasets, data dictionaries, reading examples, split lists and conversion notes.

  • 04

    Experts & Evaluation

    Expert feedback, scoring rules, evaluation sets, item-level results, disagreement arbitration and analysis.

  • 05

    Quality Management

    Inspection reports, agreed error/agreement measures, rework records and batch acceptance sheets.

  • 06

    Simulation & Synthesis

    Scene assets, synthetic data, generation configuration, source identification and version and quality notes.

  • 07

    Managed Teams

    Ongoing output, staff training, scheduling, progress and quality reports and task handoff.

Renewable energy and compute infrastructure at dusk

Power → Compute → Data

Build the data layer for what comes next.

Start with a small pilot and a sample review. We scope the specification, run the pilot, adjust on results, then deliver at batch scale.